PortfolioPATCH / SUMMER 2026

3D vision / Robotics

ArcTek Robotics - 'Patch' Summer Accelerator 2026
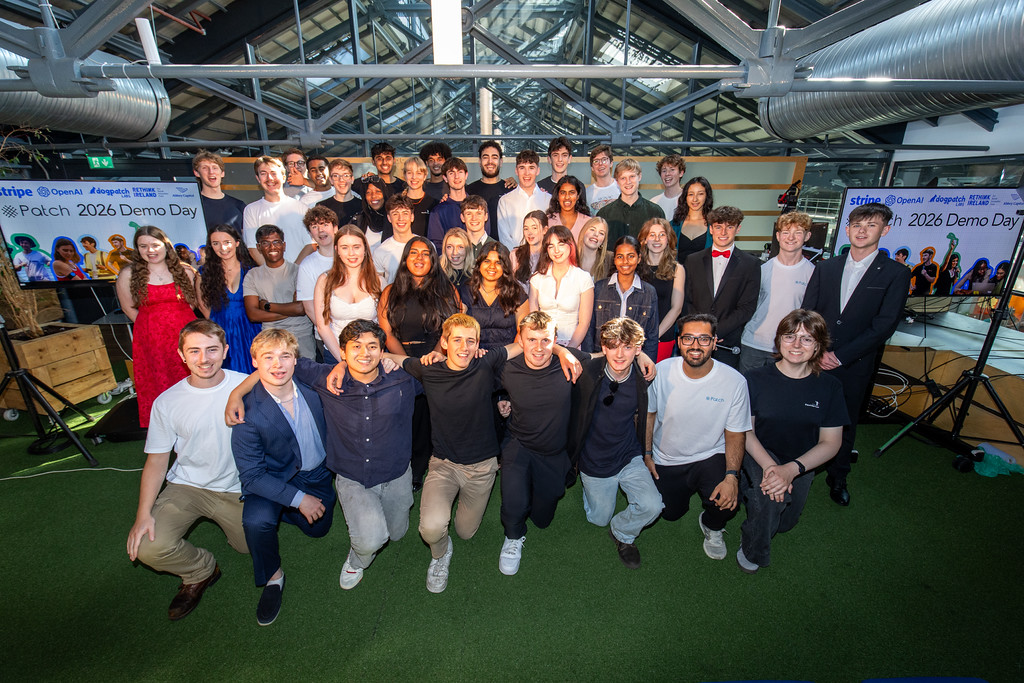
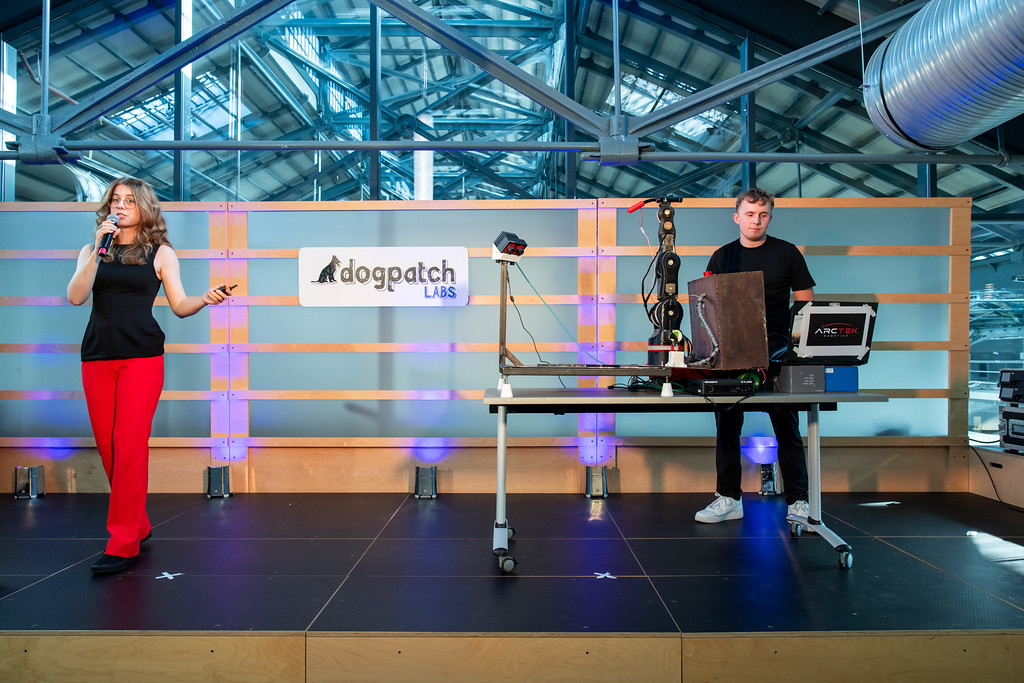
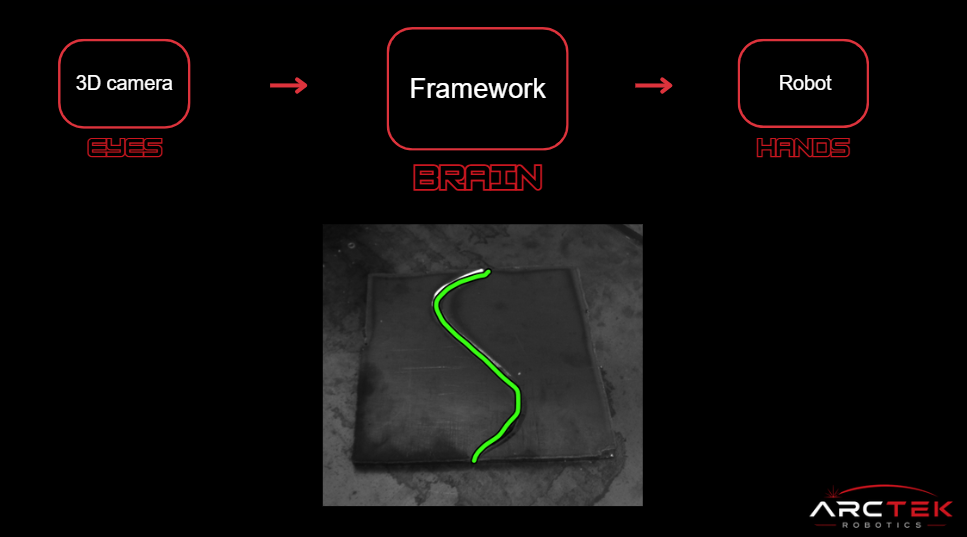
Along with 35 other young builders and engineers I was selected for the 'Patch' summer accelerator, backed by OpenAI and Stripe. The goal was to team up and build something we care about in 7 weeks, whether that's a start-up, a non-profit or simply a passion project. Together with my 3 teammates I built a 3D vision-integrated robotics system as a prototype for robotic welding with significantly reduced programming times. My main role was the integration of the 3D stereo camera to provide a point cloud of the part to be welded.
Step 01

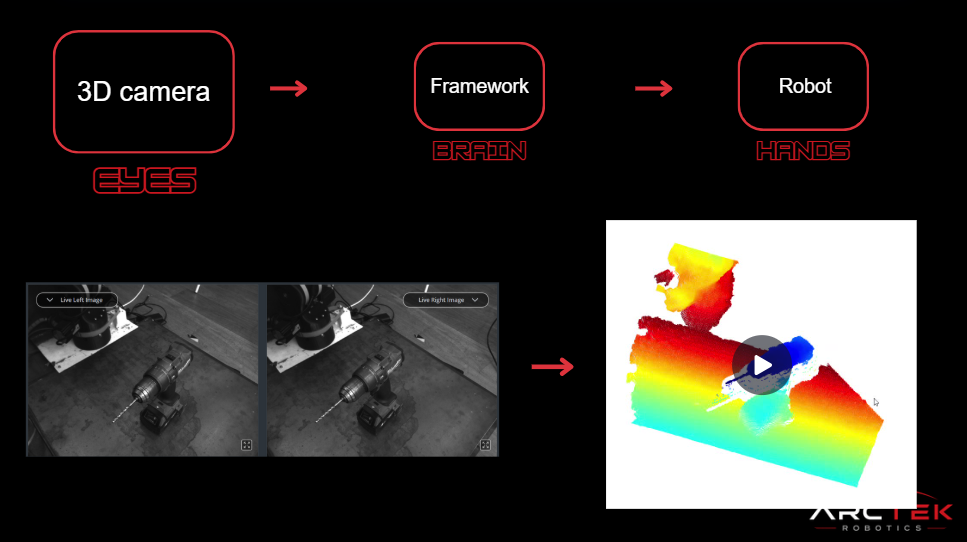
The eyes

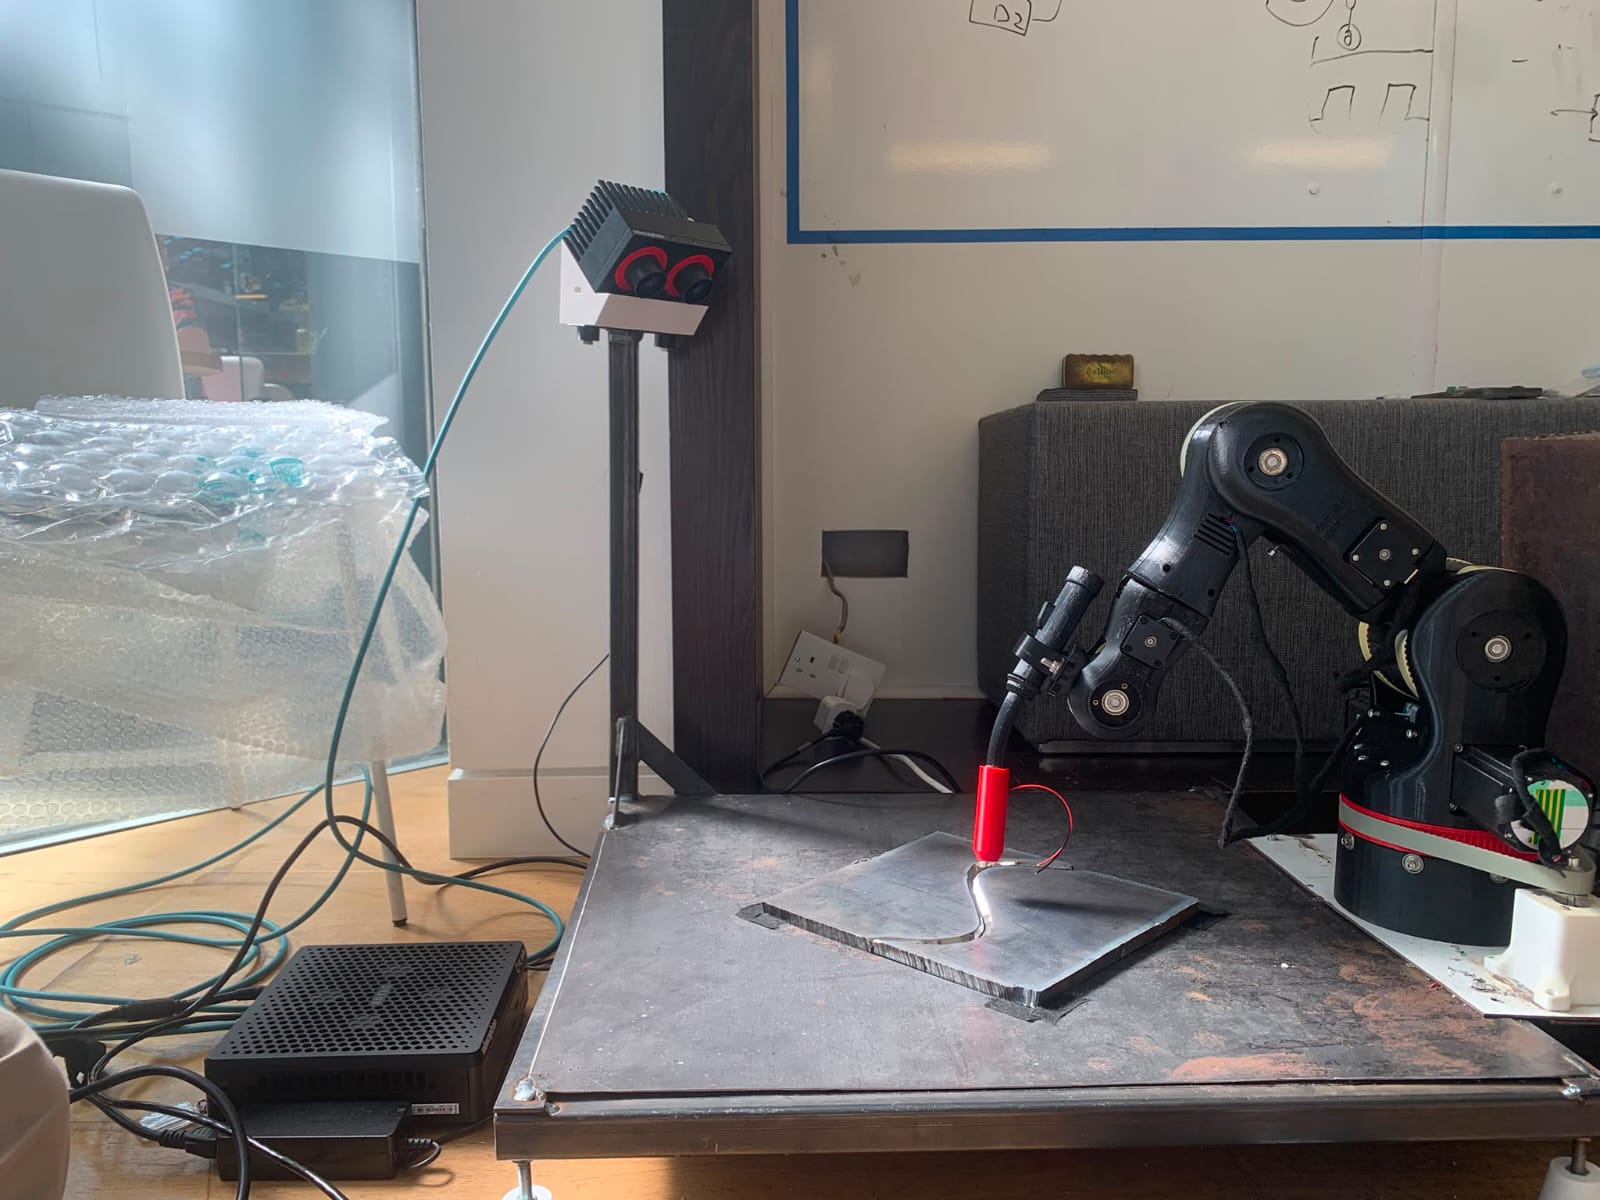
I coordinated with Roboception, a robotics vision company, to borrow one of their stereo cameras. It takes two offset images and computes the depth of the pixels, just like the human brain does from the left and right eyes. We had to set up our testbed, install a custom mount for the camera and handle the data export to a Python environment. Another challenge was the calibration to convert between camera and robot coordinate systems.

Step 02

The brain

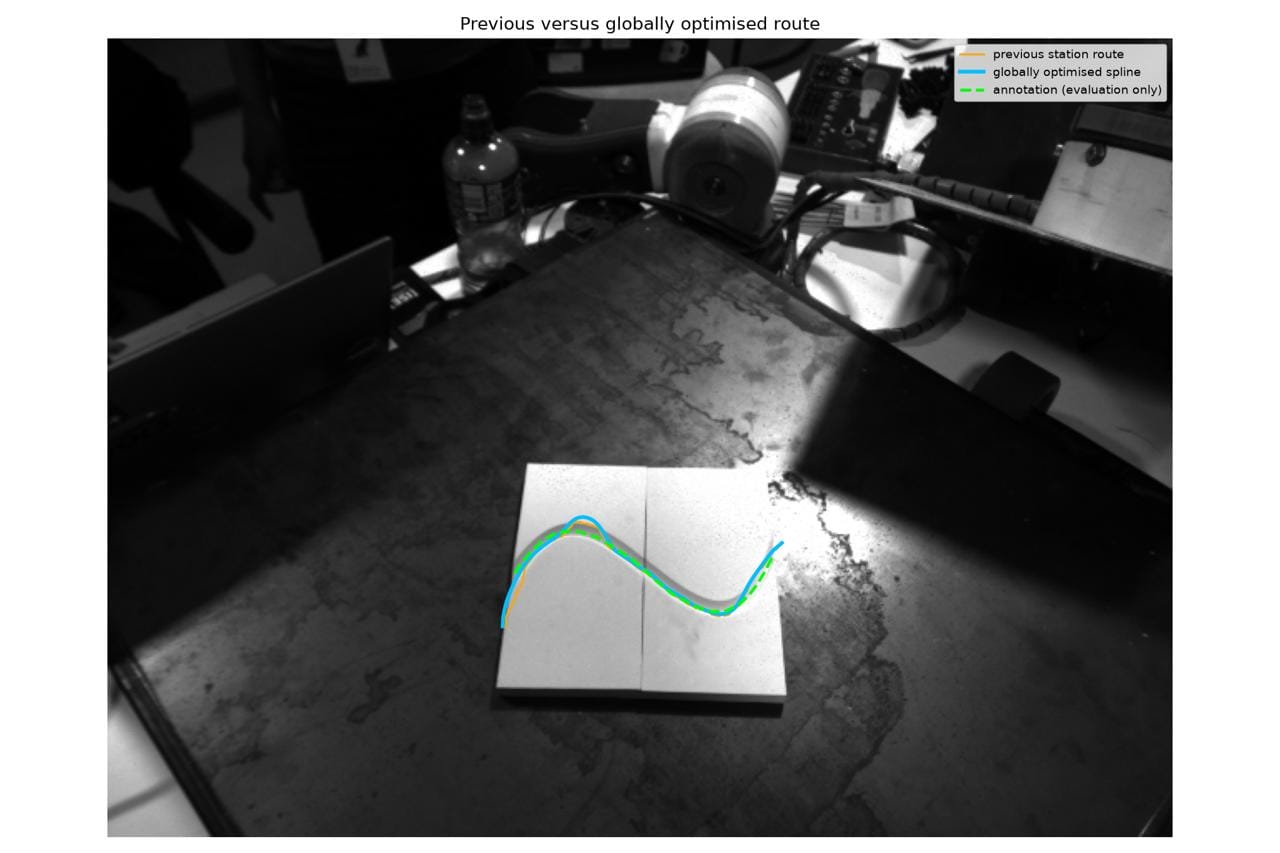
A geometry-based algorithm was applied to the point cloud to identify edges of the part which could be welded. This cuts out the need to import a CAD model or spend a lot of time programming for each new part.

Step 03

The hands

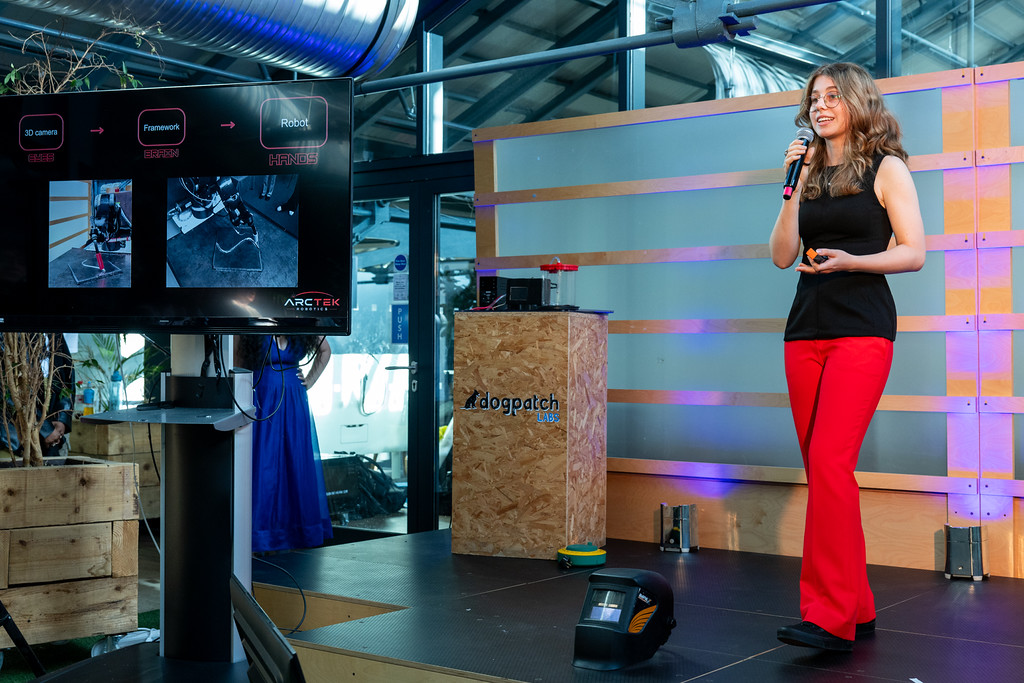
We used an open-source BCN3D Moveo arm to follow the path given by the algorithm. I designed a 3D-printed mock welding torch with a removable tip which holds a laser pointer. This way we could demo the vision system without the budget for an industrial arm.

View 01
View 02